Takumi Asada ☕️

Takumi Asada

Ph.D Student in Engineering

Utsunomiya University

Professional Summary

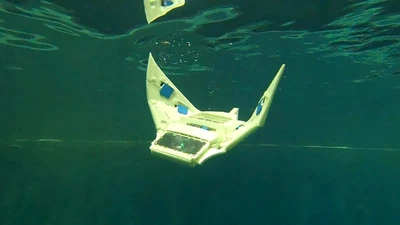
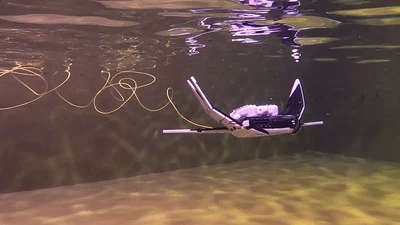
Takumi Asada is a Ph.D. student at Utsunomiya University, where he conducts research in biomimetics, intelligent robotics, and underwater robotic systems. His work focuses on bio-inspired robots, including manta ray-inspired robots, integrating motion control, neural oscillators, and Sim2Real techniques.

Education

Doctor of Engineering (D.Eng.), in progress

2025-04-01
2027-03-31

Utsunomiya University

Master of Engineering (M.Eng.)

2021-04-01
2023-03-31

Aichi Institude of Technology

Bachelor of Engineering (B.Eng.)

2017-04-01
2021-03-31

Aichi Institude of Technology

Interests

Intelligent Robotics Biomimetics Robot Underwater Robot Factory Automation Laboratory Automation
Publications
Multimodal locomotion control of multi-jointed BURs with swimming and legged capabilities featured image

Multimodal locomotion control of multi-jointed BURs with swimming and legged capabilities

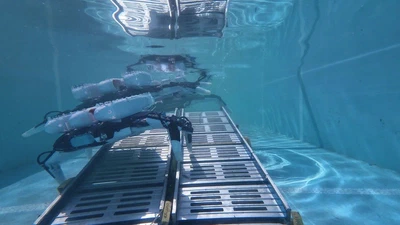
Multimodal biomimetic underwater robots (BURs) combine swimming and legged locomotion for underwater exploration. Rule-based behavior selection limits new behavioral capabilities. …

avatar
Takumi Asada
•
Motivation-based Action Selection and Emergence of Locomotion Behavior for BURs featured image

Motivation-based Action Selection and Emergence of Locomotion Behavior for BURs

Conventional multifunctional BURs rely on explicitly programmed, task-level behaviors, limiting how flexibly actions are selected and how much behavioral diversity can emerge. This …

avatar
Takumi Asada
•
Obstacle Avoidance Using Population Vector Code-Based SNN-CPG Controller for Robotic Fish in Unknown Environment featured image

Obstacle Avoidance Using Population Vector Code-Based SNN-CPG Controller for Robotic Fish in Unknown Environment

Neurorobotics uses spiking neural networks to reproduce biological intelligence and behaviors, but neural-circuit-based obstacle avoidance for multi-jointed robots remains …

avatar
Takumi Asada
•
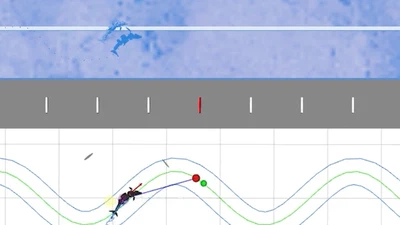
Path Following Control System of Line-of-Sight Guidance for Robotic Dolphin with Multi-Link Mechanism in Underwater Simulator featured image

Path Following Control System of Line-of-Sight Guidance for Robotic Dolphin with Multi-Link Mechanism in Underwater Simulator

A path following control system based on line-of-sight guidance is proposed for a robotic dolphin with a multi-link body mechanism, verified through underwater simulation …

avatar
Takumi Asada
•
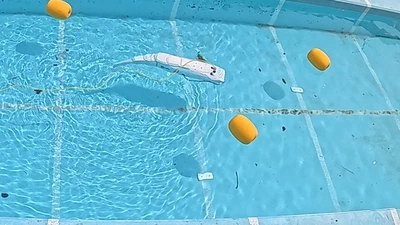
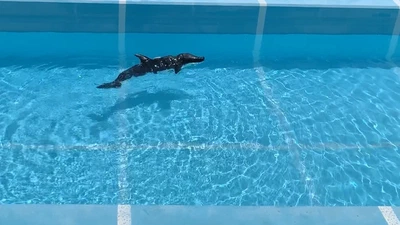
Performance Evaluation Using Sim2Real of a Robotic Dolphin With Multi-Link Body Mechanism and CPG-Based Controller featured image

Performance Evaluation Using Sim2Real of a Robotic Dolphin With Multi-Link Body Mechanism and CPG-Based Controller

A robotic dolphin equipped with a multi-link body mechanism and CPG-based controller is evaluated through sim-to-real transfer, demonstrating effective swimming performance from …

avatar
Takumi Asada
•
Propulsion and Station-Keeping Control for Small Unmanned Surface Vehicles: Design and Experimental Evaluation featured image

Propulsion and Station-Keeping Control for Small Unmanned Surface Vehicles: Design and Experimental Evaluation

This paper presents the design and experimental evaluation of propulsion and station-keeping control strategies for small unmanned surface vehicles (USVs).

takao-oki
•
Design and Control of Multi-Rigid Link Pectoral Fins Using Virtual Spring-Damper System for a Manta Ray Robot featured image

Design and Control of Multi-Rigid Link Pectoral Fins Using Virtual Spring-Damper System for a Manta Ray Robot

A manta ray robot with multi-rigid link pectoral fins is proposed to actively reproduce uniquely defined bending motions. A virtual spring-damper system enables the fins to mimic …

avatar
Takumi Asada
•
Development of a Manta Ray Robot with Underwater Walking Function featured image

Development of a Manta Ray Robot with Underwater Walking Function

Underwater robots can be categorized into bio-inspired, thruster-based, and legged systems. Among them, bio-inspired robots are attractive due to their high efficiency, mobility, …

avatar
Takumi Asada
•
Development of a Multi-Finned Omni-Directional Mobile Underwater Robot featured image

Development of a Multi-Finned Omni-Directional Mobile Underwater Robot

A multi-finned omni-directional mobile underwater robot is developed, leveraging multiple fin-based actuators to achieve flexible omnidirectional locomotion in aquatic …

m.-kuno
•
Projects
Underwater Robot featured image

Underwater Robot

Achievements and activities in underwater robotics competitions, including design, development, and operation of bio-inspired and autonomous underwater robots.

Laboratory Automation featured image

Laboratory Automation

Research and development activities in laboratory automation, including robotic experimentation, collaborative robots, and AI-assisted materials discovery. Accelerating Condition …

Food Robotics featured image

Food Robotics

Projects and demonstrations involving collaborative robots in food preparation and service applications.

Experience

JSPS's DC2 Fellowship

JSPS - Japan Society for the Promotion of Science

Engaged in research on multifunctional and multimodal control of multi-joint biomimetics underwater robots.

Software Engineer

DENSO CORPORATION

Engaged in mass production development of software update and reprogramming.

Education

Doctor of Engineering (D.Eng.), in progress

Utsunomiya University

Master of Engineering (M.Eng.)

Aichi Institude of Technology

Bachelor of Engineering (B.Eng.)

Aichi Institude of Technology

Awards
Yutaka Saito Scholarship, Utsunomiya University 3C Fund
Utsunomiya University ∙ 2026-09
Awarded the Yutaka Saito Scholarship from the Utsunomiya University 3C Fund.
Best Award, Freestyle Category, 8th Okinawa Ocean Robot Competition
Okinawa Ocean Robot Competition ∙ 2022-11
Team AIT-BMR II (Aichi Institute of Technology) won the Best Award in the Freestyle Category.
1st Place, Biomimetic Category 1, Underwater Robot Convention in JAMSTEC 2022
Underwater Robot Convention in JAMSTEC ∙ 2022-08
Team Black (Aichi Institute of Technology) took 1st place in the Biomimetic Category 1.
Best Award, COBOTTA Idea Challenge
COBOTTA Idea Challenge ∙ 2022-03
Crepe Project (Aichi Institute of Technology) won the Best Award.
Winner, Free Category, Underwater Robot Convention in JAMSTEC 2021
Underwater Robot Convention in JAMSTEC ∙ 2021-08
Team White α (Aichi Institute of Technology) won the Free Category.
Winner, General Competition (Free Category), Underwater Robot Convention in JAMSTEC 2020
Underwater Robot Convention in JAMSTEC ∙ 2020-12
AIT-MR III (Aichi Institute of Technology) won the General Competition (Free Category).
Award of Excellence, Freestyle Category, 6th Okinawa Ocean Robot Competition
Okinawa Ocean Robot Competition ∙ 2020-11
AIT-MR III (Aichi Institute of Technology) received the Award of Excellence in the Freestyle Category.
Academic Achievement Scholarship / Excellent Academic Performance Scholarship
Aichi Institute of Technology ∙ 2020-06
Selected as a scholarship recipient for academic achievement and outstanding grades.
Academic Achievement Scholarship / Excellent Academic Performance Scholarship
Aichi Institute of Technology ∙ 2019-06
Selected as a scholarship recipient for academic achievement and outstanding grades.
MIZUWAKA-kai Scholarship
Aichi Institute of Technology ∙ 2018-06
Selected as a MIZUWAKA-kai scholarship recipient.
Grants-in-Aid and Scholarships
  • Research on Hybrid Control of a Multifunctional Multi-Joint Biomimetic Robot Japan Society for the Promotion of Science (JSPS), KAKENHI Grant-in-Aid for JSPS Fellows (Research Fellowship for Young Scientists) Apr 2026 – Mar 2028 / Principal Investigator: Takumi Asada