Selected publications

I enjoy making things. Here are a selection of publications that I have worked on over the years.

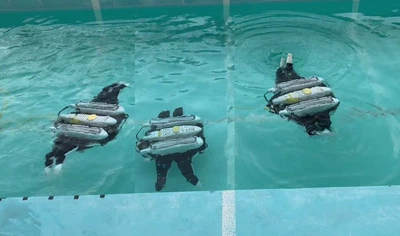
Multimodal locomotion control of multi-jointed BURs with swimming and legged capabilities featured image

Multimodal locomotion control of multi-jointed BURs with swimming and legged capabilities

Multimodal biomimetic underwater robots (BURs) combine swimming and legged locomotion for underwater exploration. Rule-based behavior selection limits new behavioral capabilities. …

Motivation-based Action Selection and Emergence of Locomotion Behavior for BURs featured image

Motivation-based Action Selection and Emergence of Locomotion Behavior for BURs

Conventional multifunctional BURs rely on explicitly programmed, task-level behaviors, limiting how flexibly actions are selected and how much behavioral diversity can emerge. This …

Obstacle Avoidance Using Population Vector Code-Based SNN-CPG Controller for Robotic Fish in Unknown Environment featured image

Obstacle Avoidance Using Population Vector Code-Based SNN-CPG Controller for Robotic Fish in Unknown Environment

Neurorobotics uses spiking neural networks to reproduce biological intelligence and behaviors, but neural-circuit-based obstacle avoidance for multi-jointed robots remains …

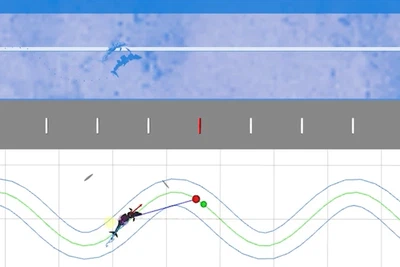
Path Following Control System of Line-of-Sight Guidance for Robotic Dolphin with Multi-Link Mechanism in Underwater Simulator featured image

Path Following Control System of Line-of-Sight Guidance for Robotic Dolphin with Multi-Link Mechanism in Underwater Simulator

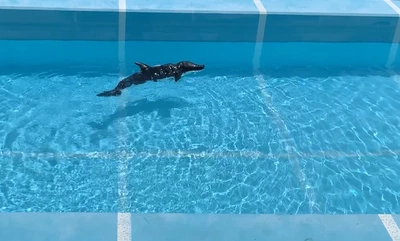
A path following control system based on line-of-sight guidance is proposed for a robotic dolphin with a multi-link body mechanism, verified through underwater simulation …

Performance Evaluation Using Sim2Real of a Robotic Dolphin With Multi-Link Body Mechanism and CPG-Based Controller featured image

Performance Evaluation Using Sim2Real of a Robotic Dolphin With Multi-Link Body Mechanism and CPG-Based Controller

A robotic dolphin equipped with a multi-link body mechanism and CPG-based controller is evaluated through sim-to-real transfer, demonstrating effective swimming performance from …

Propulsion and Station-Keeping Control for Small Unmanned Surface Vehicles: Design and Experimental Evaluation featured image

Propulsion and Station-Keeping Control for Small Unmanned Surface Vehicles: Design and Experimental Evaluation

This paper presents the design and experimental evaluation of propulsion and station-keeping control strategies for small unmanned surface vehicles (USVs).

Design and Control of Multi-Rigid Link Pectoral Fins Using Virtual Spring-Damper System for a Manta Ray Robot featured image

Design and Control of Multi-Rigid Link Pectoral Fins Using Virtual Spring-Damper System for a Manta Ray Robot

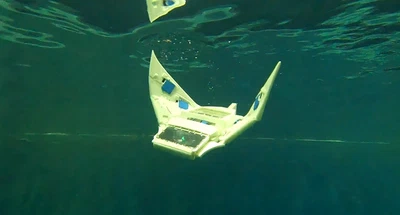
A manta ray robot with multi-rigid link pectoral fins is proposed to actively reproduce uniquely defined bending motions. A virtual spring-damper system enables the fins to mimic …

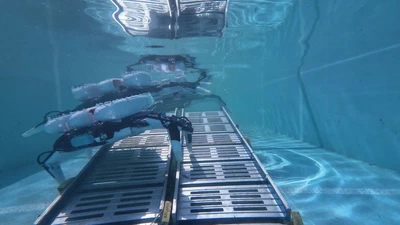
Development of a Manta Ray Robot with Underwater Walking Function featured image

Development of a Manta Ray Robot with Underwater Walking Function

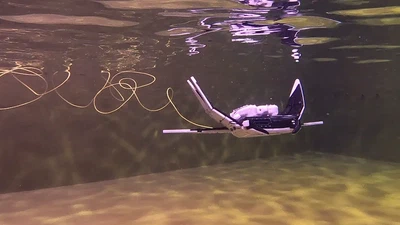
Underwater robots can be categorized into bio-inspired, thruster-based, and legged systems. Among them, bio-inspired robots are attractive due to their high efficiency, mobility, …

Development of a Multi-Finned Omni-Directional Mobile Underwater Robot featured image

Development of a Multi-Finned Omni-Directional Mobile Underwater Robot

A multi-finned omni-directional mobile underwater robot is developed, leveraging multiple fin-based actuators to achieve flexible omnidirectional locomotion in aquatic …