Conference

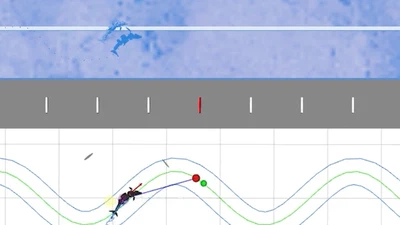
Path Following Control System of Line-of-Sight Guidance for Robotic Dolphin with Multi-Link Mechanism in Underwater Simulator featured image

Path Following Control System of Line-of-Sight Guidance for Robotic Dolphin with Multi-Link Mechanism in Underwater Simulator

A path following control system based on line-of-sight guidance is proposed for a robotic dolphin with a multi-link body mechanism, verified through underwater simulation …

avatar
Takumi Asada
•
Propulsion and Station-Keeping Control for Small Unmanned Surface Vehicles: Design and Experimental Evaluation featured image

Propulsion and Station-Keeping Control for Small Unmanned Surface Vehicles: Design and Experimental Evaluation

This paper presents the design and experimental evaluation of propulsion and station-keeping control strategies for small unmanned surface vehicles (USVs).

takao-oki
•
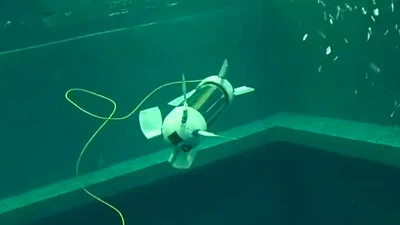
Development of a Multi-Finned Omni-Directional Mobile Underwater Robot featured image

Development of a Multi-Finned Omni-Directional Mobile Underwater Robot

A multi-finned omni-directional mobile underwater robot is developed, leveraging multiple fin-based actuators to achieve flexible omnidirectional locomotion in aquatic …

m.-kuno
•