Abstract
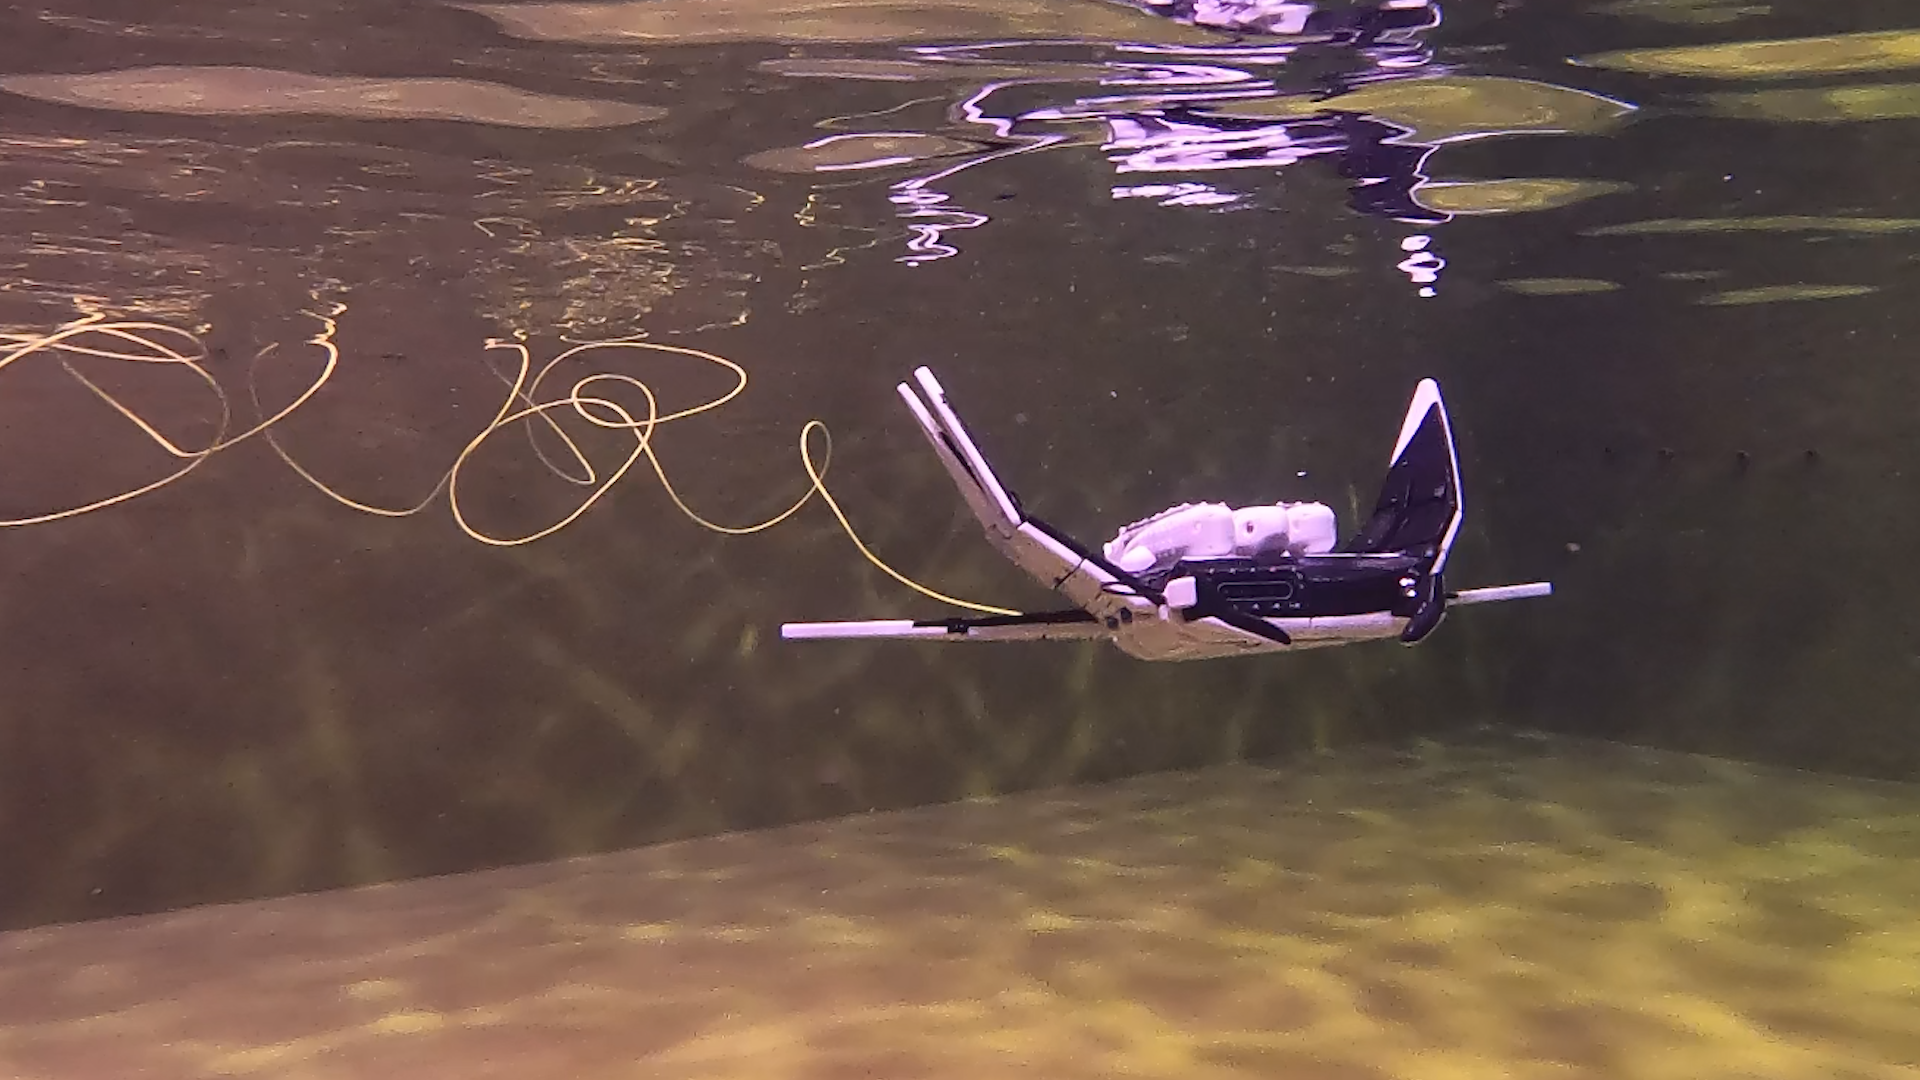
Underwater robots can be classified into various types, such as bio-inspired, thruster, and legged-type robots. The bio-inspired type is efficient, mobile, and low noise. There is a Hybrid-type that combines with the walking functions of the legged-type. Manta ray robots can efficiently swim using their large pectoral fins, but they struggle with seafloor exploration. To address this deficiency a new prototype manta ray robot that integrates the underwater walking function of legged-type robot is proposed. The left and right pectoral fins are each divided into three parts and designed to have six leg-fins. The system is not complex and low-energy consumption, without the additional new leg functions as in the past. Swimming and walking models are constructed using a kinematics model. The experimental performance is evaluated in a real-world environment. The developed manta ray robot demonstrated good swimming and walking capabilities, establishing itself as a prototype for future bio-inspired robots with walking function.
Structual Design
This study presents the design of a manta ray robot equipped with an underwater walking function. The robot uses a bio-inspired structure that integrates legged-type mechanisms into its pectoral fins to enable both swimming and walking capabilities.
The body is constructed using a lightweight ABS resin exoskeleton fabricated with 3D printing, which improves durability, reduces deformation, and ensures corrosion resistance in underwater environments. Each pectoral fin is divided into three segments, forming a total of six “leg-fins,” each controlled by three actuators to enable roll and pitch motions. In addition, a head-mounted actuator supports camera-based seabed observation, resulting in a total of 19 actuators in the system.
The robot is designed at one-third scale for improved portability and maneuverability during underwater exploration. Its structure is modular, consisting of control, sensor, battery, and buoyancy units, enabling stable performance in both swimming and walking modes.
BibTeX
@article{asada2024development,
  title   = {Development of a manta ray robot with underwater walking function},
  author  = {Takumi Asada and Hideo Furuhashi},
  journal = {Ocean Engineering},
  volume  = {308},
  pages   = {118261},
  year    = {2024},
  doi     = {10.1016/j.oceaneng.2024.118261},
  url     = {https://linkinghub.elsevier.com/retrieve/pii/S0029801824015993}
}